Autonomous UAV Obstacle Detection & Avoidance System
Autonomous UAV Obstacle Detection & Avoidance System
MSc Robotics Project — University of Bristol
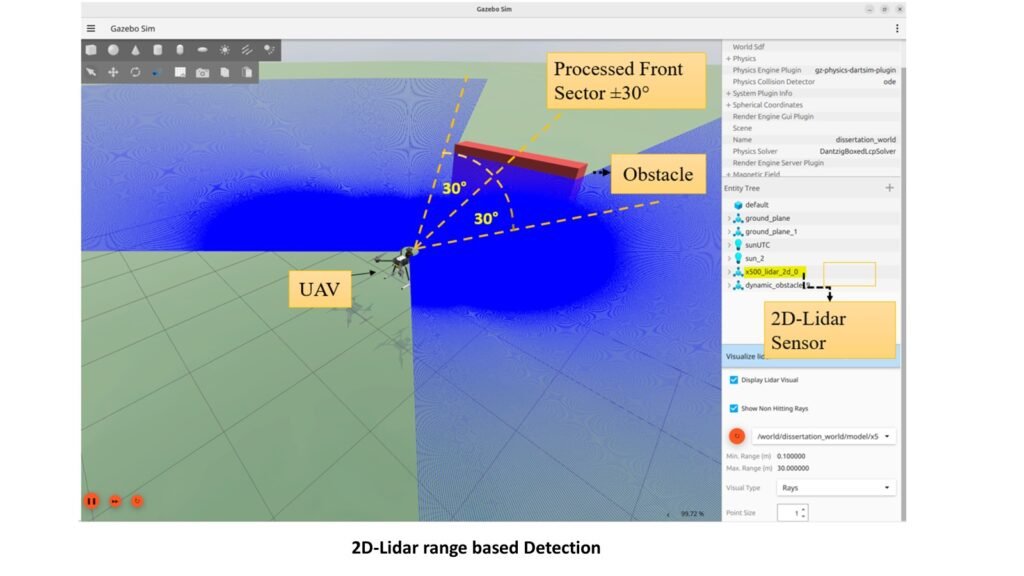
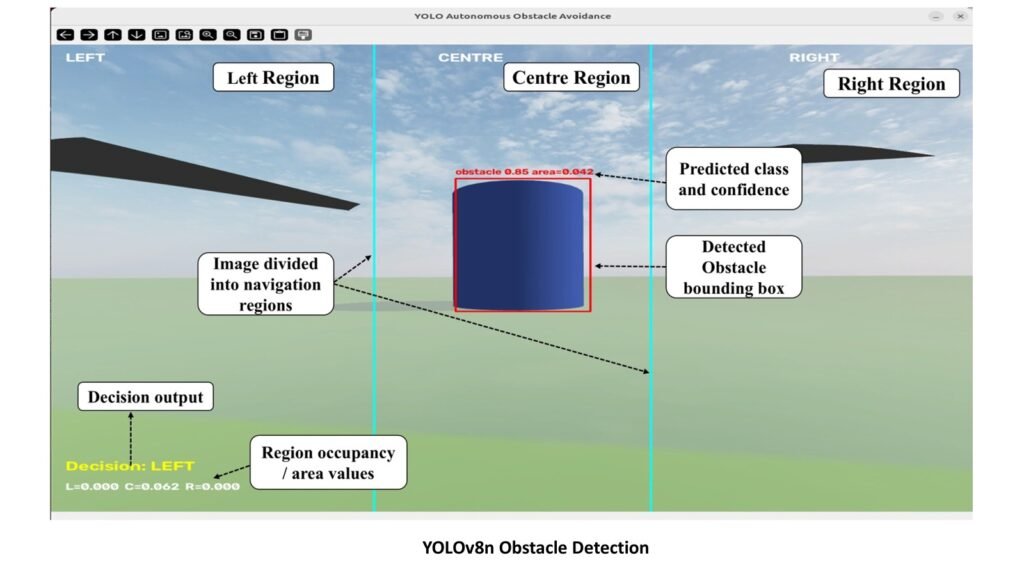
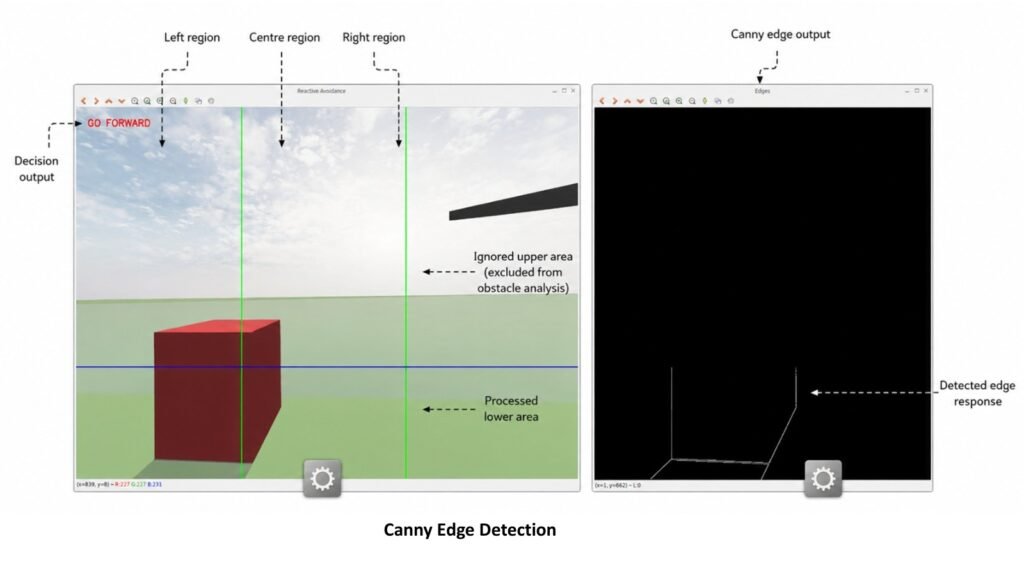
Developed and evaluated an autonomous UAV obstacle detection and avoidance system in a simulated PX4/Gazebo environment. The project compared three different approaches for detecting obstacles and reacting to them during flight:
Canny Edge Detection – traditional computer vision approach using image processing and edge analysis.
YOLOv8n – object detection using a custom-trained single-class model.
2D LiDAR – sensor-based obstacle detection using a forward scanning sector.
The system was implemented using ROS 2 Jazzy, PX4 SITL and Gazebo, with Python-based control and detection nodes.